About
PhD candidate at LAAS-CNRS (Toulouse) and the University of Trento, advised by Nicolas Mansard and Andrea Del Prete. My research is on robot learning, in particular world models from state and vision for model-based RL and planning, and universal policies that generalize across tasks and robots. I hold an MSc in Mechatronic Engineering from Politecnico di Torino (with an Erasmus+ year at Aalto University) and a BSc in Industrial Engineering from Trento.
Publications & Preprints
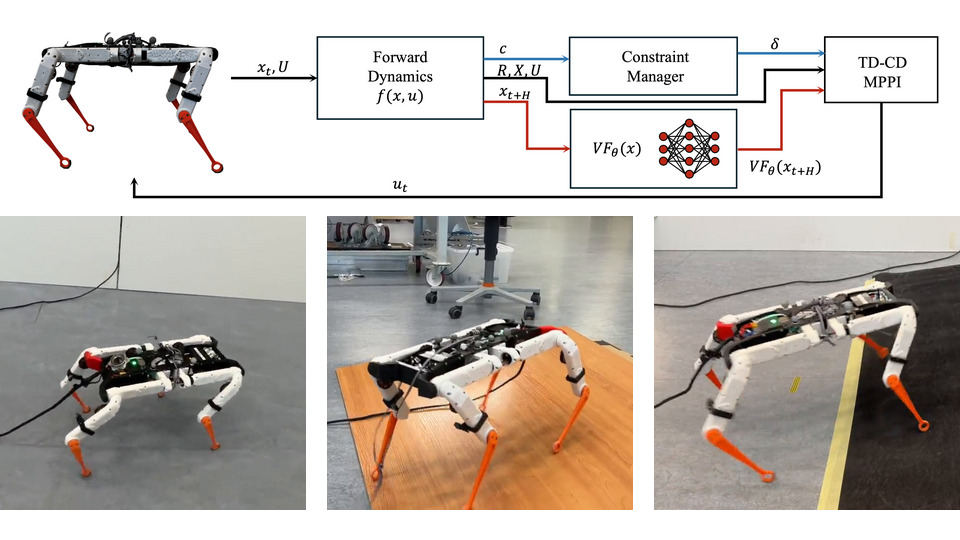
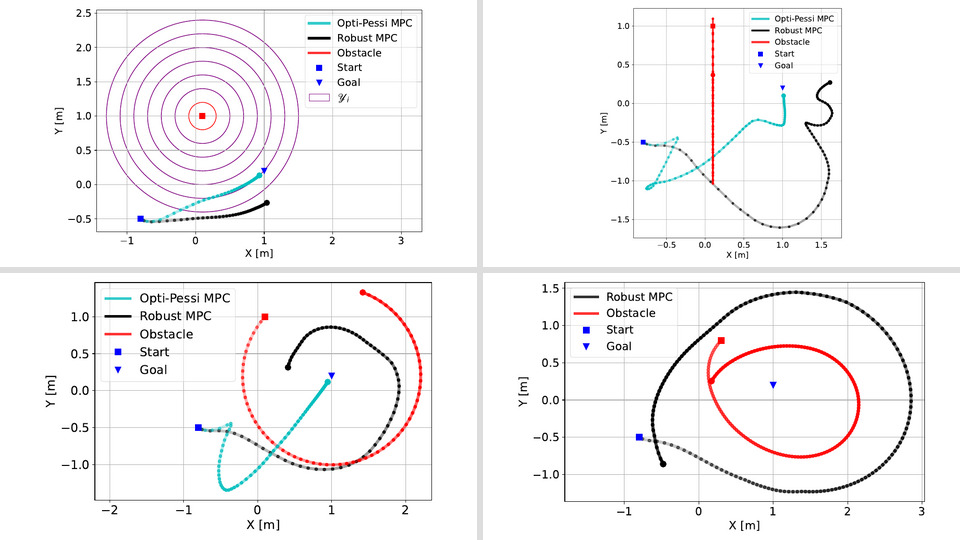
TD-CD-MPPI: Temporal-Difference Constraint-Discounted Model Predictive Path Integral Control
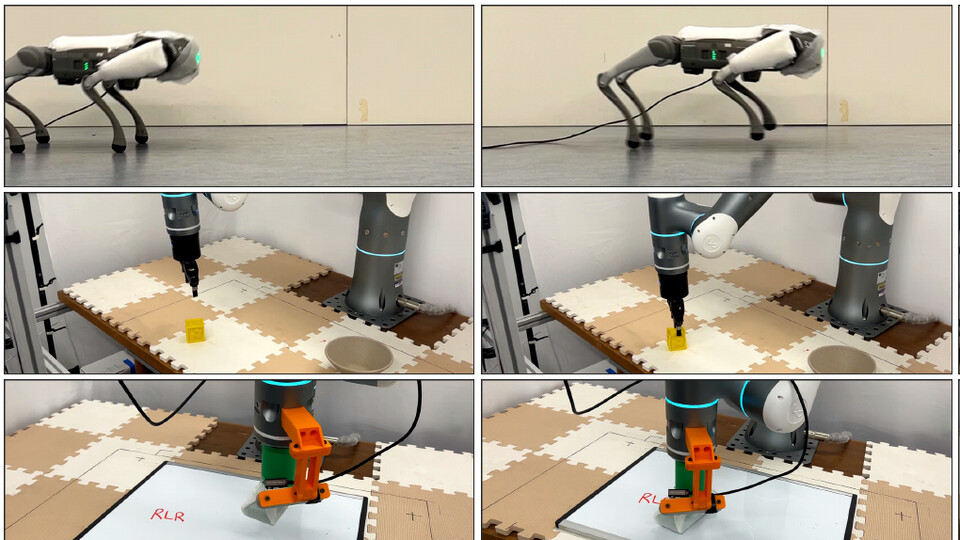
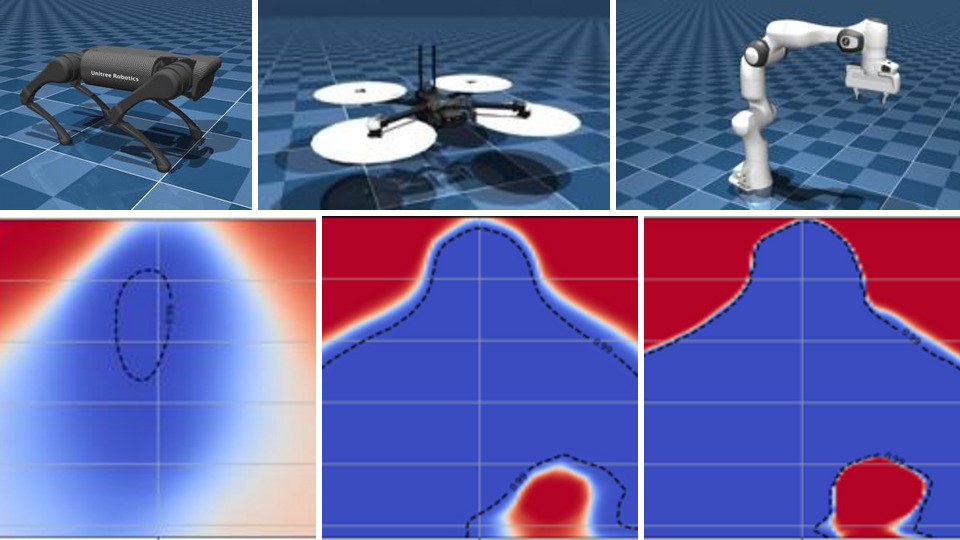
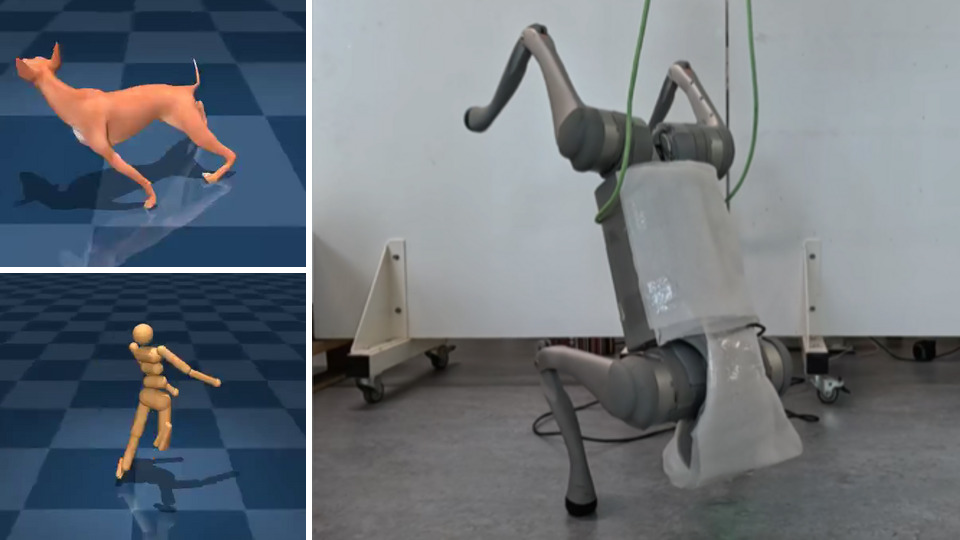
CAST: Alternating State-Value Targets and Expanded Policy Gradients for Model-Based Reinforcement Learning
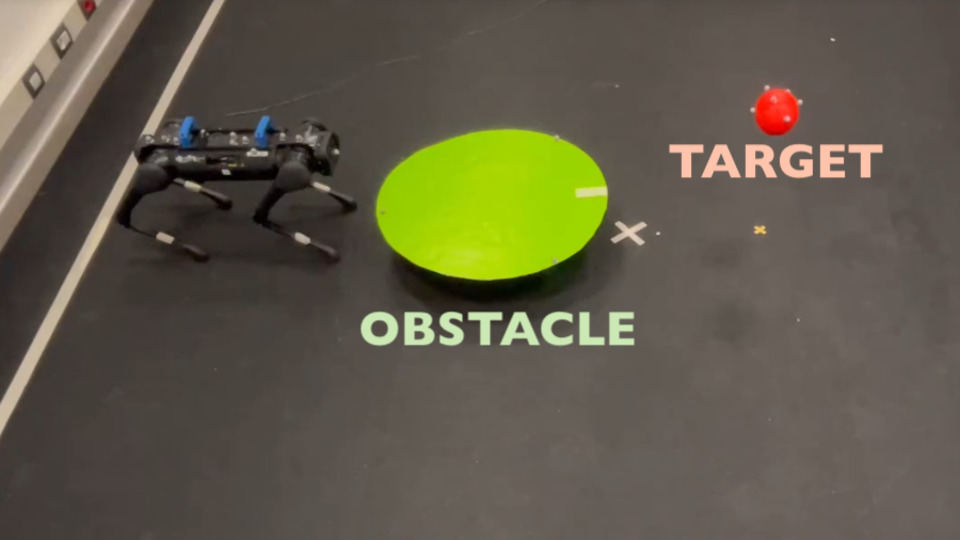
CACTO-BIC: Scalable Actor-Critic Learning via Biased Sampling and GPU-Accelerated Trajectory Optimization
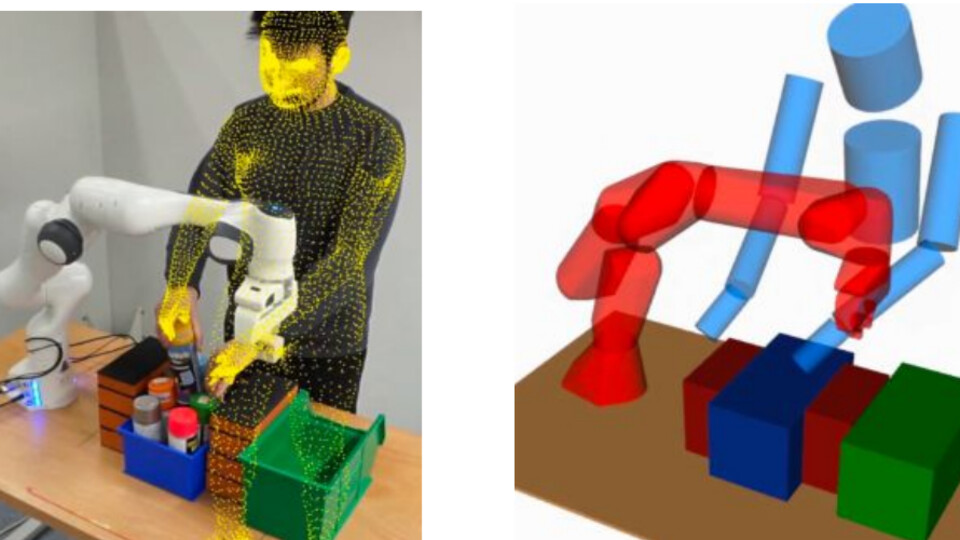
COSMIK-MPPI: Scaling Constrained Model Predictive Control to Collision Avoidance in Close-Proximity Dynamic Human Environments
ICRA 2026 — Vienna, Austria
- Poster TD-CD-MPPI: Temporal-Difference Constraint-Discounted Model Predictive Path Integral Control
- Workshop CACTO-BIC: Scalable Actor-Critic Learning via Biased Sampling and GPU-Accelerated Trajectory Optimization — Xplore Workshop
JNRH 2026 — Journées Nationales de la Robotique Humanoïde, Montpellier, France
- Oral + Poster TD-CD-MPPI: Temporal-Difference Constraint-Discounted Model Predictive Path Integral Control
- Tutorial TA Zero-Order Optimization Techniques for Robotics — teaching assistant for the half-day tutorial session
Reviewer for ICRA, IEEE Robotics and Automation Letters (RA-L), IEEE Transactions on Robotics (T-RO), and IEEE-RAS Humanoids.
Research & Professional Experience
PhD Researcher — Numerically Efficient Robot Learning
- World models & model-based RL for sample-efficient policy learning and planning (CAST, with a sim-to-real Go2 handstand).
- Universal policies that adapt in context (Transformer-XL) and control different morphologies with one network.
- Learning + sampling-based planning with GPU-parallel MPPI (TD-CD-MPPI on Solo12), and distillation of planners into visuomotor policies (VAMPS).
Teaching Assistant — Robot Learning & Control
Tutor for Optimisation and Learning for Robot Control and Advanced Optimization-Based Robot Control (MSc Mechatronics, MSc AI Systems).
Graduate Student Researcher
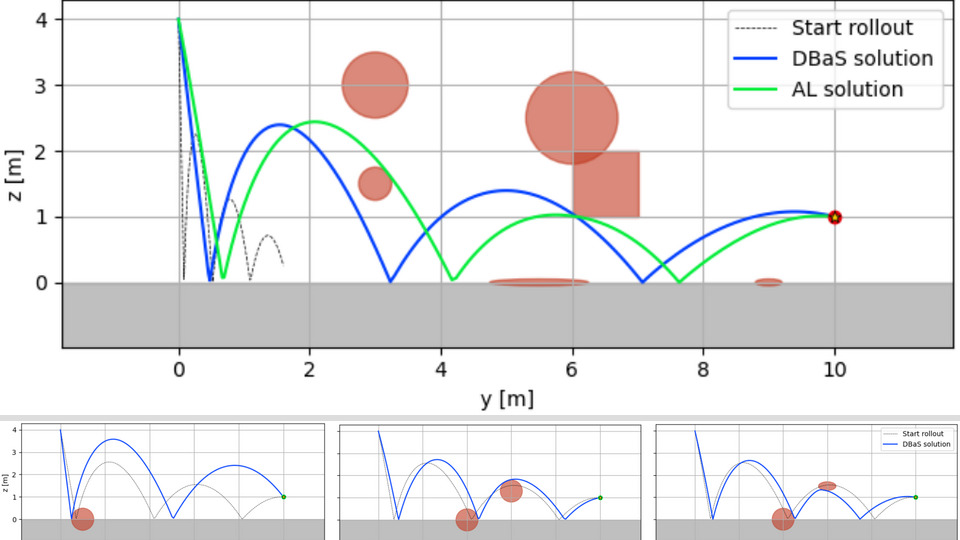
Fast DDP-based solver for constrained trajectory optimization of hybrid systems with contact, using exact derivatives and saltation matrices. MSc thesis work, published as arXiv:2410.22894.
Motion Planning & Control Engineer
Algorithms for Autonomous Driving division of a Formula SAE driverless team. Trajectory planning and MPC-based tracking control for a fully autonomous race car.
Junior Data Analyst
Climate risk assessment for Philip Morris International facilities worldwide. Geo-visualization pipelines for multi-model climate hazards across temperature scenarios up to 2050.
Education
PhD in Robotics & Optimal Control (Cotutelle)
Supervisors: Nicolas Mansard (LAAS-CNRS) and Andrea Del Prete (University of Trento). Numerically efficient RL for robotics, combining model-free and model-based methods with MPPI trajectory optimizers.
MSc in Mechatronic Engineering
Specialization in Software Technologies for Automation. Erasmus+ year at Aalto University (GPA 5.0/5.0).
Thesis: Constrained Trajectory Optimization for Hybrid Dynamical Systems, a DDP-based solver for
non-smooth dynamics with contact constraints. Supervised by Prof. M. Canale (PoliTo), co-supervised by
Prof. V. Kyrki (Aalto) and Assist. Prof. G. Alcan (Tampere).
BSc in Industrial Engineering
Specialization in Mechatronic Engineering.
Thesis: Automatic Differentiation: Theory and Applications in Nonlinear Programming, bridging
CasADi and Autodiff with IPOPT. Supervised by Prof. E. Bertolazzi, co-supervised by Prof. F. Biral.
Skills
Earlier Projects
Projects from my Bachelor's and Master's years, before starting the PhD.
- MPC for Robotic Arm Control. Linearized MPC for a 4 and 5 DoF robotic arm, simulated and run on a physical model built by the team with 3D-printed links and servo motors, with David Costa (PoliTo) and Loïc Delineau (EPFL). Video report.
- MPC for Formula SAE Racing Car Control. Linearized MPC for the racing car's longitudinal and transversal dynamics, reducing lap time under vehicle and environmental constraints. MATLAB, co-generating C code for onboard real-time performance.
- C++ IPOPT Interface Using AD with CasADi. Part of the bachelor thesis on automatic differentiation. Algorithms for large sparse matrices, bridging CasADi and Autodiff with the IPOPT nonlinear optimization package.